 TBSD60
 BSD120
 BSD98
 BSD70
 BSD60
 BSD50
 BSD217
 INS1700
 INS970
 INS570
 INS170
 SLA-4B1L1-65
 SLA-8B1L1-110
 SLA-4B1L1-130
 SLA-16B1L1-160
 SLA-8B1L1-165
 101 Vessel-mounted Positioning
 102 Acoustic Communication
 103 Tracking and Locating
 104 Diver Navigation System
 105 Intrusion Detection Sonar
 106 Delivery Locator Beacon
 SLLR3000
 SLLR905
 SLLD25
 108IMU
 150M
 500MH
 160M
 170M
 SLFC-70
 SLAF280
 MR360


Attitude Heading Reference System: Key Specs Buyers Should Compare
Why Attitude Heading Reference System Specifications Matter
When you purchase an Attitude Heading Reference System, the product specification sheet is one of the first things you should review. However, not every specification has the same value for your application.
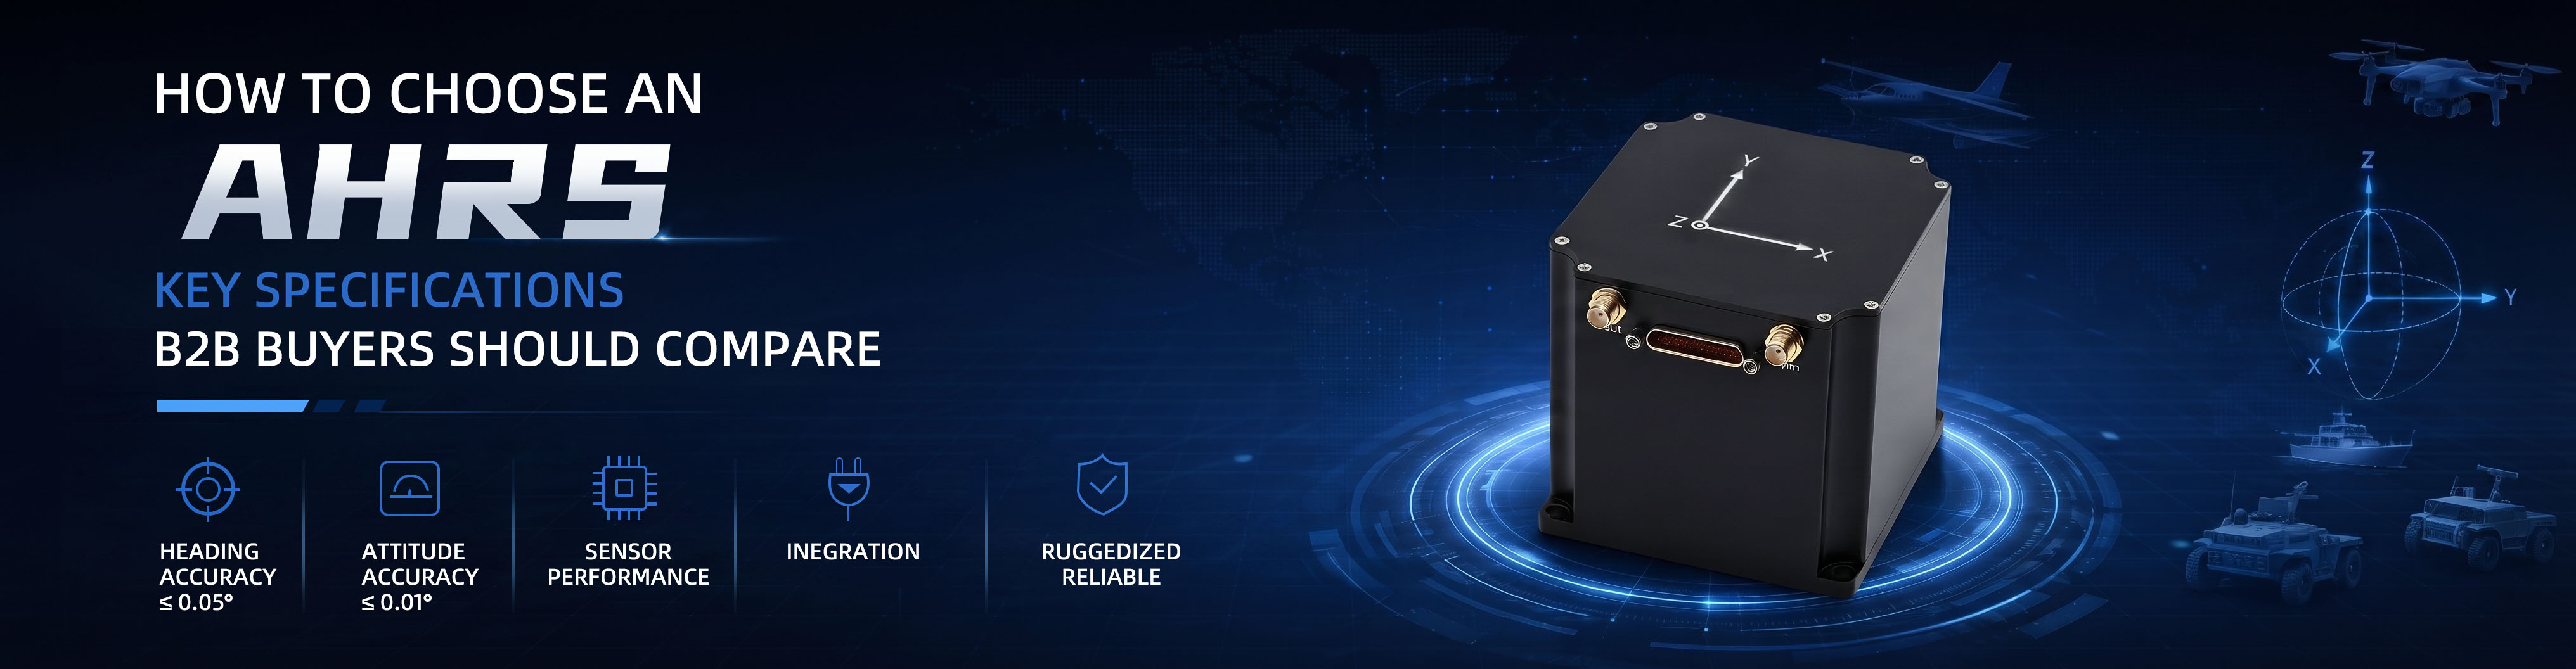
An Attitude Heading Reference System provides important orientation data, such as heading, pitch, and roll. This information supports navigation, stabilization, control, and motion measurement in UAVs, autonomous vehicles, marine equipment, surveying systems, and industrial platforms.
For B2B buyers, the goal is not simply to find the Attitude Heading Reference System with the highest specifications. The better approach is to find a system whose performance matches the real needs of your equipment.
So, which specifications should you compare?
- Compare Attitude Heading Reference System Heading Accuracy
Heading accuracy is one of the most important specifications to check when comparing an Attitude Heading Reference System.
Heading tells you the direction in which your platform is pointing. Even a small heading error can affect navigation and positioning performance, especially when the system is used for precise motion control or long-distance operation.
When comparing an Attitude Heading Reference System, check:
- Heading accuracy
- North-seeking accuracy
- Stability during motion
- Performance in dynamic conditions
For example, Poseidon navigation products combine inertial sensors with navigation algorithms to provide heading and attitude information for demanding applications. The INS970 lists 0.05° heading accuracy and 0.01° RMS attitude accuracy, while the INS670 lists 0.05° heading accuracy and 0.02° attitude accuracy.
These specifications give buyers a useful starting point for comparing products.
- Check Attitude Accuracy for Your Application
An Attitude Heading Reference System does more than provide heading information. It also measures the orientation of the platform through pitch and roll data.
Attitude accuracy can be especially important for:
- UAV flight control
- Antenna stabilization
- Camera and sensor platforms
- Marine equipment
- Autonomous vehicles
- Industrial motion systems
Before selecting an Attitude Heading Reference System, buyers should compare the stated attitude accuracy with the actual requirements of their equipment.
A system with suitable accuracy can provide more stable orientation data and reduce errors in downstream control or navigation functions.
- Evaluate Sensor Performance and Data Quality
The sensor configuration inside an Attitude Heading Reference System directly affects its measurement performance.
When comparing products, buyers should look beyond the product name and check what sensors and processing technologies are used.
Important factors include:
- Gyroscope performance
- Accelerometer performance
- Sensor bias stability
- Measurement range
- Data output rate
- Sensor fusion algorithms
For demanding applications, stable sensor data is important because the navigation controller depends on this information to calculate platform movement and orientation.
Poseidon products use combinations of fiber optic gyroscopes and MEMS accelerometers in integrated navigation systems. This type of sensor combination can support high-precision navigation while allowing the system to provide real-time heading, attitude, velocity, and position information.
- Review Interfaces and Integration Requirements
A technically strong Attitude Heading Reference System may still be difficult to use if it does not match your existing equipment.
Before placing an order, check:
- Communication interfaces
- Power requirements
- Mechanical dimensions
- Data protocols
- Software compatibility
- External sensor support
For B2B projects, easy integration can reduce development time and engineering costs.
For example, Poseidon INS970 supports multiple interfaces and external sensors such as odometers, DVL, and USBL. This allows the navigation system to be adapted to different equipment and navigation architectures.
- Check Environmental Adaptability
Your Attitude Heading Reference System must work reliably in the environment where your equipment operates.
Temperature changes, vibration, shock, and long operating periods can all affect sensor performance.
When comparing an Attitude Heading Reference System, review:
- Operating temperature
- Vibration resistance
- Shock resistance
- Long-term stability
- Environmental testing
This is especially important for UAVs, marine platforms, industrial vehicles, and other equipment that may operate under demanding conditions.
A suitable Attitude Heading Reference System should maintain stable performance rather than only achieving good results in controlled laboratory conditions.
- Consider the Supplier Behind the Attitude Heading Reference System
For B2B buyers, the supplier is part of the purchasing decision.
A reliable Attitude Heading Reference System supplier should offer clear specifications, technical documentation, integration support, and stable product supply.
It is also useful to check whether the supplier has experience across different navigation applications.
Poseidon Navigation provides integrated navigation products designed for applications including UAVs, marine navigation, engineering surveying, autonomous vehicles, and other demanding platforms.
This type of application experience can be valuable when your project requires more than a standard off-the-shelf sensor.
Conclusion: Compare Specifications Based on Your Real Needs
Choosing an Attitude Heading Reference System should be based on the complete system requirement, not one specification alone.
Before making a purchasing decision, compare:
- Heading accuracy
- Attitude accuracy
- Sensor performance
- Interfaces
- Environmental adaptability
- Supplier support
The best Attitude Heading Reference System is the one that provides the right combination of accuracy, reliability, integration, and application compatibility.
For B2B buyers, taking time to compare these factors can reduce integration risks, improve system performance, and support long-term project success.